Hubert Szolc

Hubert Szolc

Hubert Szolc, MSc
Research & Teaching Assistant
PhD Student
szolc@agh.edu.pl

I’m interested in controlling autonomous vehicles - especially Unmanned Aerial Vehicles (UAVs) - primarily based on visual information. I use FPGAs and heterogeneous computing platforms to implement the algorithms in hardware.

Automatic Control Computer Vision Event Cameras Hardware Acceleration Real-Time Processing SoC FPGA UAVs

Experience 2

  1. Research & Teaching Assistant

    2021 – Present
    AGH University of Krakow

    I am conducting research on utilising SoC computing platforms for vision-based autonomous control of UAVs . In my work I am using using both classical algorithms as well as AI methods and hybrid approches. I am also responsible for running labs with students on parallel computing, vision algorithms and control methods.

  2. IT&V Engineer

    July 2017 – February 2018
    Delphi/Aptiv Poland

    I worked as an Independent Test & Verification Engineer, responsible for the software and hardware used by car manufacturers.

Education 3

  1. PhD candidate

    2019 – Present
    AGH Doctoral School, AGH University of Kraków

    Automation, Electronics, Electrical Engineering and Space Technologies

  2. Master of Science

    2018 – 2019
    AGH University of Krakow

    Automatic Control and Robotics - Inteligent Control Systems - Vision Systems

  3. Bachelor of Engineering

    2014 – 2018
    AGH University of Krakow

    Automatic Control and Robotics

Awards 2

  1. 4th Place - UAV Competition, IEEE ICUAS 2024

    2024
    International Conference on Unmanned Aircraft Systems (ICUAS)

    Fourth place in the finals of the international UAV Competition, after placing 6th of 23 teams in the simulation phase. The task was autonomous fruit counting with a UAV equipped with an RGB camera and a depth sensor.

  2. 2nd Place - Multi-Robot Systems Summer School 2024 Challenge

    2024
    Multi-Robot Systems Group, Czech Technical University in Prague (IEEE RAS Summer School on Multi-Robot Systems)

    Second place in the international competition held as part of the IEEE RAS Summer School on Multi-Robot Systems in Prague, with the final round carried out in outdoor experiments with real multi-UAV systems.

Academic service 2

  1. Web Co-Chair

    2026
    DSD 2026 – Euromicro Conference on Digital System Design, Kraków
  2. TPC member

    2026–2027
    DASIP – Workshop on Design and Architectures for Signal and Image Processing

Publications

Year
Type
Project

2026

  1. Automation
    Vision-based automatic fruit counting with UAV
    In Automation 2025: recent advances in automation, robotics and measurement techniques, Sep 2026

2025

  1. SPA
    Embedded perception and control system for an autonomous surface vehicle using visual-LiDAR fusion and SLAM
    Olivier Lichota, Mateusz Wasala, Hubert Szolc, and Tomasz Kryjak
    In SPA 2025 : Signal Processing - algorithms, architectures, arrangements, and applications : Poznan, 17th–19th September 2025 : conference proceedings, Sep 2025

2024

  1. SPA
    tpg.png
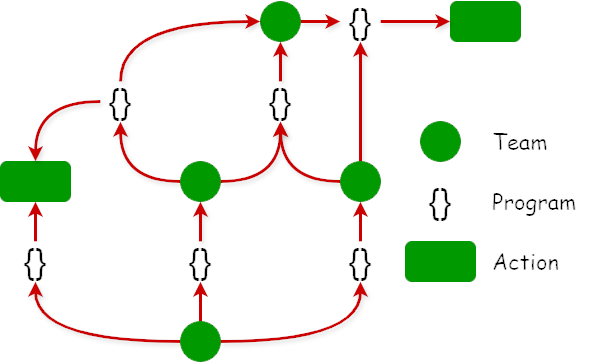
    Tangled Program Graphs as an alternative to DRL-based control algorithms for UAVs
    Hubert Szolc, Karol Desnos, and Tomasz Kryjak
    In 2024 Signal Processing: Algorithms, Architectures, Arrangements, and Applications (SPA) , Sep 2024

2023

  1. PAR
    Sterowanie autonomicznym bezzalogowym statkiem powietrznym z wykorzystaniem uczenia przez wzmacnianie
    Pawel Miera, Hubert Szolc, and Tomasz Kryjak
    PAR Pomiary Automatyka Robotyka, Sep 2023

2022

  1. Electronics
    An efficient real-time FPGA-based ORB feature extraction for an UHD video stream for embedded visual SLAM
    Electronics, Sep 2022
  2. JSPS
    Automotive perception system evaluation with reference data from a UAV’s camera using ArUco markers and DCNN
    Journal of Signal Processing Systems for Signal, Image, and Video Technology, Sep 2022
  3. SPA
    Hardware-in-the-loop simulation of a UAV autonomous landing algorithm implemented in SoC FPGA
    In SPA 2022 : Signal Processing Algorithms, Architectures, Arrangements, and Applications : 25th IEEE SPA conference : Poznan, 21st - 22nd September 2022 : conference proceedings, Sep 2022
  4. Electronics Sonata
    Real-time CLAHE algorithm implementation in SoC FPGA device for 4K UHD video stream
    Electronics, Sep 2022
  5. Book chapter Preludium
    Systemy wizyjne w zastosowaniach przemyslowych
    Marek Gorgon, Maciej Aleksandrowicz, Krzysztof Blachut, Andrzej Brodzicki, Zbigniew Bublinski, and 20 more authors
    In Nauka – technika – technologia : seria wydawnicza AGH, Sep 2022

2021

  1. MMAR
    A simple vision-based navigation and control strategy for autonomous drone racing
    Artur Cyba, Hubert Szolc, and Tomasz Kryjak
    In MMAR 2021 : 2021 25th international conference on Methods and Models in Automation & Robotics : August 23–26, 2021, Międzyzdroje, Poland, Sep 2021
  2. DASIP
    Automotive perception system evaluation with reference data obtained by a UAV
    In DASIP 2021 : workshop on Design and Architectures for Signal and Image Processing - 14th edition : January 18–20 2021, Budapest, Hungary : proceedings, Sep 2021
  3. Real-time FPGA implementation of parallel connected component labelling for a 4K video stream
    Marcin Kowalczyk, Piotr Ciarach, Dominika Przewlocka-Rus, Hubert Szolc, and Tomasz Kryjak
    Journal of Signal Processing Systems for Signal, Image, and Video Technology, Sep 2021

2020

  1. ICCVG
    A vision based hardware-software real-time control system for the autonomous landing of an UAV
    In Computer Vision and Graphics : International Conference : ICCVG 2020 : Warsaw, Poland, September 14–16, 2020 : proceedings, Sep 2020
  2. ICCVG
    Optimisation of a Siamese neural network for real-time energy efficient object tracking
    In Computer Vision and Graphics : International Conference : ICCVG 2020 : Warsaw, Poland, September 14–16, 2020 : proceedings, Sep 2020